Precision Robot End Effectors Built for Your Automation
RobotPartsCNC manufactures custom end-of-arm tooling for robotics integrators, research teams, and automation product developers. We turn CAD designs into lightweight, rigid, precision-fit hardware for gripping, vacuum handling, tool operation, and specialized automation.
±0.005 mm
Precision fits available
3–7 days
Prototype lead time
5-axis
Complex geometry support
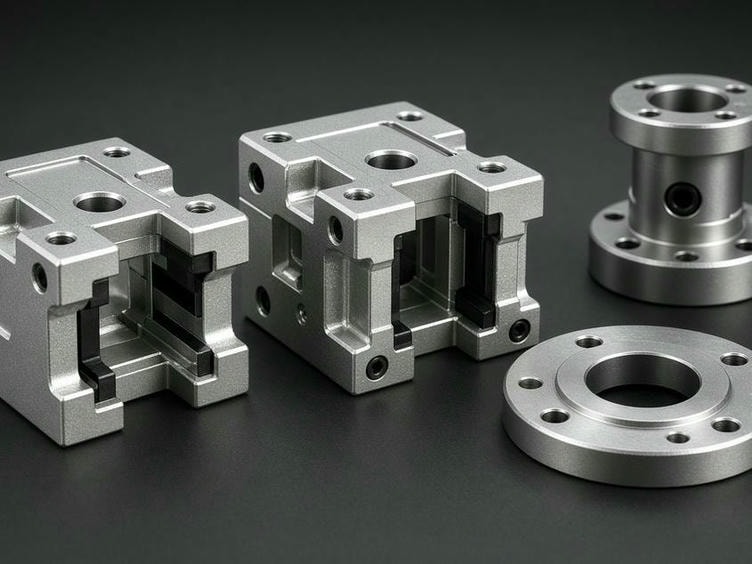
Designed around your robot, payload, and workpiece
From delicate electronics assembly to reinforced industrial tool changers.
Why custom machined EOAT matters
More control at the end of the robot arm
Standard off-the-shelf grippers often cannot satisfy the geometry, material, or integration requirements of complex parts. Custom machining gives your team direct control over handling performance and deployment speed.
Discuss your tooling requirementsWeight Reduction
6061-T6 and 7075-T6 aluminum reduce arm load while improving payload efficiency and cycle speeds.
Geometric Precision
Custom fingers and jaws follow the exact contour of your workpiece for secure, repeatable handling.
Material Compatibility
Choose stainless steel, POM, PEEK, and other materials for corrosion resistance, insulation, or non-marring contact.
Direct Integration
Precisely machined interfaces align with existing robot flanges without bulky adapter plates.
Manufacturing capabilities
Built for high-mix, low-volume robotics development
Our Shenzhen facility supports rapid prototype iterations as well as production batches for custom grippers, vacuum tooling, tool changers, brackets, shafts, and specialized automation mechanisms.
| Capability | Specification |
|---|---|
| Milling | 3, 4, and 5-axis CNC milling for complex geometries |
| Turning | Precision turning for circular adapters and shafts |
| Tolerance | Standard ±0.01 mm; precision fits down to ±0.005 mm |
| Maximum Size | Up to 1000 × 600 × 600 mm |
| Surface Finish | Anodizing, hard coating, bead blasting, and laser marking |
| Lead Time | 3–7 working days for prototypes |
Design iteration support
Resolve manufacturing risks before production
EOAT design is iterative. Our engineering team reviews CAD files for manufacturability before production and helps your team move from concept to deployment without avoidable re-spins.
Thin-wall stability
Check that components maintain rigidity under clamping pressure.
Tool access
Optimize internal radii and geometry to reduce machining time and cost.
Assembly fit
Verify bearing seats, sensor mounts, pneumatic ports, and related interfaces.
Material selection
Match the material to the application
Aluminum · 6061, 7075
Lightweight, high-stiffness grippers and structural components.
Stainless Steel · 303, 304, 316
Sterile, corrosive, or high-wear environments.
Engineering Plastics · POM, PEEK, Nylon
Non-marking gripper fingers and insulating sensor mounts.
Carbon and Alloy Steel
High-load structural brackets and tool changers.
Quality assurance
Reliable interfaces for precision automation
Every part is inspected against your specifications because end effectors often interface with expensive sensors and high-precision robot arms.
Dimensional Accuracy
CMM inspection plus calibrated height and bore gauges.
Traceability
Inspection reports and material certificates available on request.
Surface Treatment
Managed hard-coat anodizing and secondary processes for wear resistance.
Project questions
Plan your EOAT project with confidence
Request a quote
Move your robot tooling from CAD to deployment
Send your technical drawings or 3D CAD models and our engineering team will review your design for manufacturability.
Include: material and surface finish requirements
Include: prototype or production quantity
Include: specific tolerance or fit requirements
Email: info@robotpartscnc.com
Address:
Tell us about your end effector
Share your requirements with our engineering team to receive a DFM review and competitive quote within 24 hours.