Precision CNC Machined Robot Gripper Parts & EOAT Components
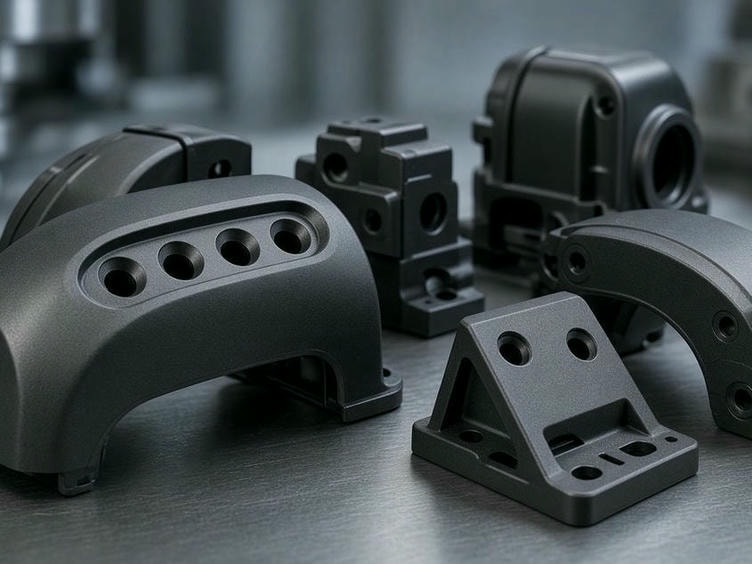
RobotPartsCNC provides high-precision CNC machining for robot grippers, end-of-arm tooling (EOAT), and custom automation components. We manufacture complex gripper bodies, fingers, jaws, and tool changer adapters from your CAD models and engineering drawings.
From custom robotic grippers for assembly and material handling to laboratory automation equipment, our Shenzhen-based facility supports demanding tolerance and material requirements.
±0.01 mm
Standard tolerance control
3–7 days
Rapid prototype lead time
Built for EOAT systems
Small parts. Exact interfaces. Reliable motion.
Robot gripper assemblies depend on accurate fitment, repeatable alignment, and low-friction movement. We machine the precision parts that make these systems dependable in production.
High-precision details
Critical bearing fits, alignment pins, mounting patterns, threads, and thin-wall features are reviewed for functional accuracy.
Many part geometries
From gripper bodies and fingers to sliders, adapters, brackets, and sensor mounts, we support varied EOAT architectures.
Low-volume friendly
Rapid prototypes, pilot runs, and custom automation projects from 10 to 500 units are supported without unnecessary overhead.
Fast customization
Engineering review and DFM feedback help shorten iteration cycles and prepare complex designs for efficient CNC production.
Component coverage
Components we machine for EOAT
Precision parts are manufactured around your robot interface, gripping method, payload, and available installation space.
Gripper bodies & housings
Complex, lightweight structures with precise mounting patterns and integrated functional features.
Custom fingers & jaws
Geometry-specific gripping components for delicate, irregular, or heavy-duty part handling.
Tool changer adapters
High-strength interface plates designed for repeatable alignment between robot and tooling.
Slide mechanisms
Precision-machined blocks and guides for adjustable gripper strokes and controlled movement.
Sensor & camera mounts
Integrated housings and brackets for vision-guided robotics and proximity sensing.
Mounting brackets
Custom adapters that interface grippers with different robot arm flanges and installation layouts.
Machining capabilities
Designed around complex gripper geometry
Our manufacturing floor supports the contours, cavities, interfaces, and material behavior commonly found in robotic end-of-arm tooling.
5-axis CNC milling
Ideal for complex finger contours, ergonomic shapes, and deep cavities.
Precision turning & mill-turn
Used for circular gripper components, drive shafts, and threaded connectors.
Tolerance control
Standard tolerances of ±0.01 mm, with capability down to ±0.005 mm for critical bearing fits or alignment pins.
Thin-wall machining
Controlled strategies help manage material stress in lightweight aluminum fingers and prevent deformation.
Material selection
Materials matched to the application
Aluminum 6061-T6 and 7075-T6
Lightweight gripper fingers and structural components.
Stainless steel 303, 304 and 316
Food-grade, medical, or corrosive environments requiring durability.
POM, PEEK and Nylon
Non-marring surfaces, electrical insulation, and weight-sensitive applications.
Tool steels and hardened alloys
High-wear applications and heavy-duty industrial gripping tasks.
Performance finishing
Surface finishes for performance and longevity
Secondary processes are integrated into the workflow to improve wear resistance, corrosion protection, appearance, and functional performance.
Hard anodizing
Improves wear resistance and surface hardness for aluminum fingers.
Electroless nickel plating
Provides uniform coating and corrosion resistance for internal mechanisms.
Bead blasting
Creates a uniform matte finish to reduce reflection in vision-guided systems.
Passivation
Supports stainless steel components used in medical and cleanroom robotics.
Quality assurance
Inspection built around repeatable motion
Every robot gripper part is checked against the specifications that govern fitment, alignment, and reliable operation.
GD&T adherence
Flatness, parallelism, and true position requirements are reviewed and controlled.
Precision measurement
CMM, optical measuring equipment, and calibrated bore and thread gauges verify critical dimensions.
Quality documentation
Dimensional inspection reports, material certificates, and Certificates of Conformance are available upon request.
Project flexibility
From prototype to production
Rapid prototyping
3–7 day lead times for early-stage engineering validation and fit tests.
Low-volume production
Pilot runs and customized automation projects requiring 10 to 500 units.
Production manufacturing
Scalable repeat orders with fixture optimization and batch inspection for consistency across thousands of parts.
DFM support for robotics engineers
Before production, our engineering team reviews CAD files for deep cavities, thin walls, difficult tool access, and other manufacturability risks. Suggested design modifications can reduce cost and shorten lead times.
Technical questions
Answers for your next gripper project
Request a quote
Turn your gripper design into production-ready parts.
Send your project requirements to receive a competitive assessment for robot gripper parts, fingers, slides, adapters, and other EOAT components.
Include: 3D CAD files, preferably STEP, STP, or IGES.
Include: 2D drawings with tolerances and critical dimensions.
Include: Material, surface finish, and required quantity.
Start your project discussion
Share your drawings and requirements with our engineering team.
RobotPartsCNC
Shenzhen, China
info@robotpartscnc.com